Tag: プログラミング

  • What Exactly Is YORU, a New Behavior Analysis Tool Powered by Object Detection?

    What Exactly Is YORU, a New Behavior Analysis Tool Powered by Object Detection?

    In November 2024, a preprint was posted on bioRxiv describing YORU, a behavior analysis tool that takes a different approach from existing behavior analysis tools.
    In this post, I would like to explain what kind of tool it is.

    YORU preprint

    YORU documentation

    What is YORU?

    YORU is a deep learning-based tool for analyzing animal behavior.
    YORUのサイトより引用


    Many deep learning-based tools, such as DeepLabCut and SLEAP, have already been released.
    These tools use deep learning to track animal body parts and estimate posture (here I will call them tracking tools).
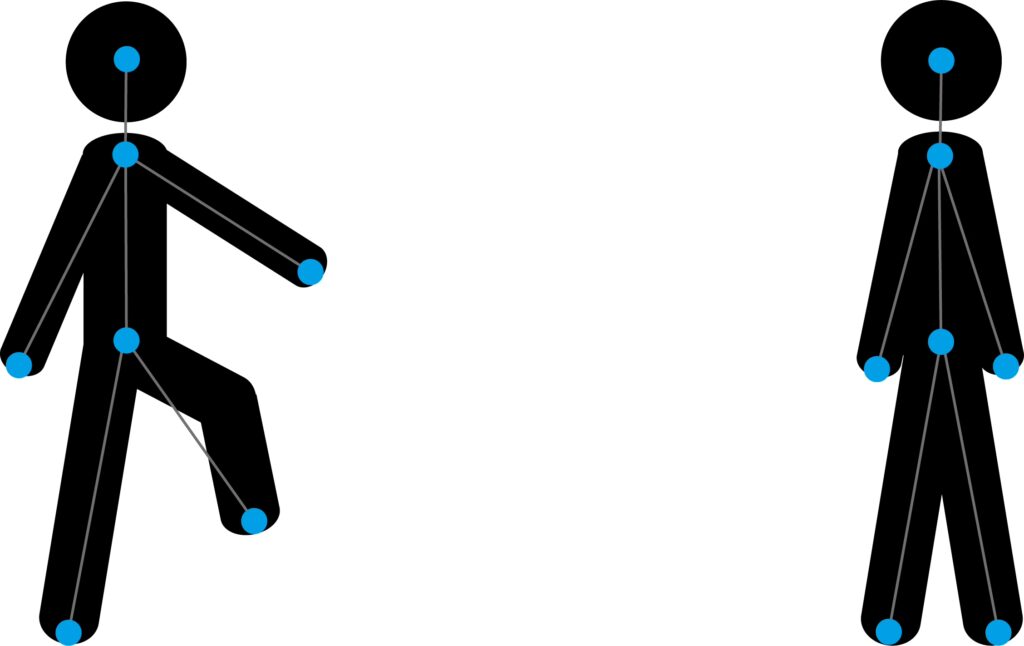
    By estimating posture, they reveal what posture an animal is in and use this for behavior analysis.

    YORU, by contrast, recognizes behavior using an object detection algorithm.
    In short, it does not track body parts; instead, it defines behavior directly from the appearance of the behaving animal.

    When we distinguish an apple from an orange, we rely on cues such as shape and color.
    Object detection excels at classifying objects, so it makes exactly this kind of appearance-based distinction.

    Applying this to animal behavior analysis means classifying animal behavior from its appearance.
    Within YORU, this is referred to as a “behavior object.”
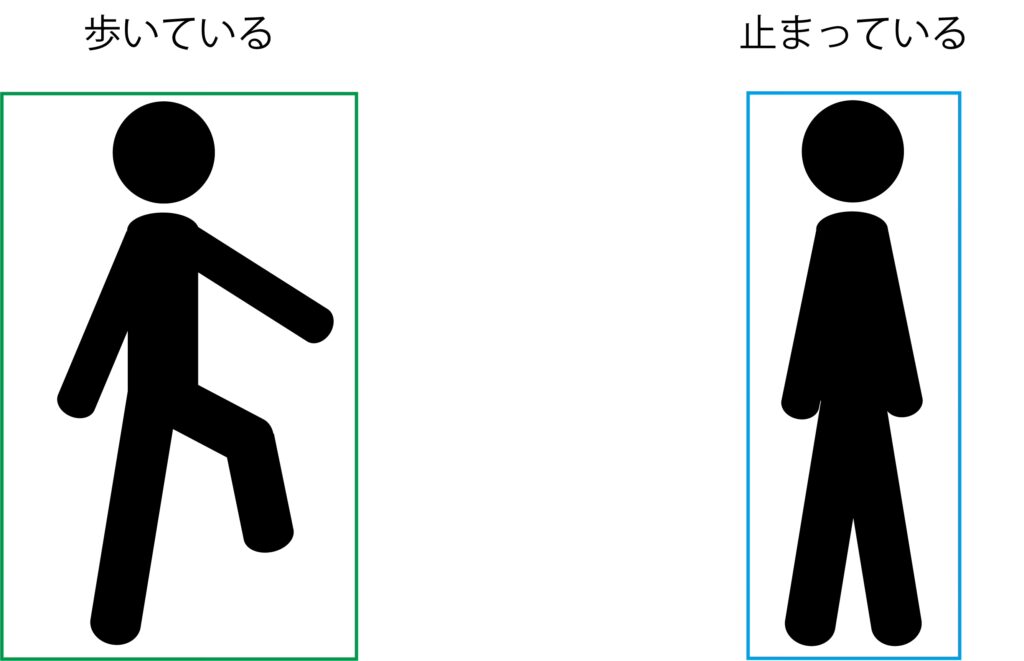
    Whereas tracking tools represent behavior as points and lines, YORU analyzes behavior by enclosing it in a bounding box.

    Advantages of defining behavior with object detection

    The advantages of object detection-based behavior analysis include:

    ・Errors are less likely even as the number of individuals increases

    ・Less affected by the animal’s orientation

    ・Fast analysis speed

    ・Can capture behaviors that are hard to detect by tracking (such as a mouse crouching)

    and so on.

    It overcomes a weakness of tracking tools by making multi-animal behavior analysis simple and far less computationally costly.
    It also makes it easy to analyze behaviors that are difficult to define from body part coordinates.

    Consider, for example, the actions of opening and closing a hand.
    With a tracking tool, you would track the fingertips with a camera and define the hand as open or closed, but if the fingertips become hidden when the hand closes, tracking fails and the positional information can no longer be computed accurately.

    With object detection, however, the model looks at the overall shape of the open and closed hand, so it can still make an accurate call even when part of the hand is occluded.

    As for robustness to increasing numbers of individuals: with a tracking tool, as the number of animals grows you must assign each body part to the correct individual in order to capture each animal’s behavior accurately, whereas YORU analyzes only the shape of each individual, so no identity assignment or part-to-individual matching is required.

    Because analysis is also fast, real-time analysis is possible—you can trigger device control when a particular behavior occurs, enabling automation of behavioral experiments.

    Disadvantages of defining behavior with object detection

    There are, of course, drawbacks as well:

    ・Cannot capture a behavioral sequence

    ・Cannot identify individuals

    ・Cannot capture unknown behaviors

    ・Cannot capture behaviors that are not visually distinctive

    ・Provides no fine-grained detail about the defined behavior

    These are precisely the strengths of tracking tools. Rather than one approach being better than the other, the two complement each other’s advantages and disadvantages.

    Experimenters therefore need to choose the approach that best suits their situation.

    What makes YORU remarkable?

    Having covered the advantages and disadvantages of the object detection-based behavior analysis that underlies YORU, what exactly makes YORU itself stand out?

    Everything runs through a GUI

    YORU lets you perform behavior analysis without writing any code.

    The same is true of tools such as DeepLabCut and SLEAP, and it goes a long way toward making these analyses accessible to biologists.

    Design


    Unlike previous tools, YORU’s design doesn’t really look like that of a research tool.
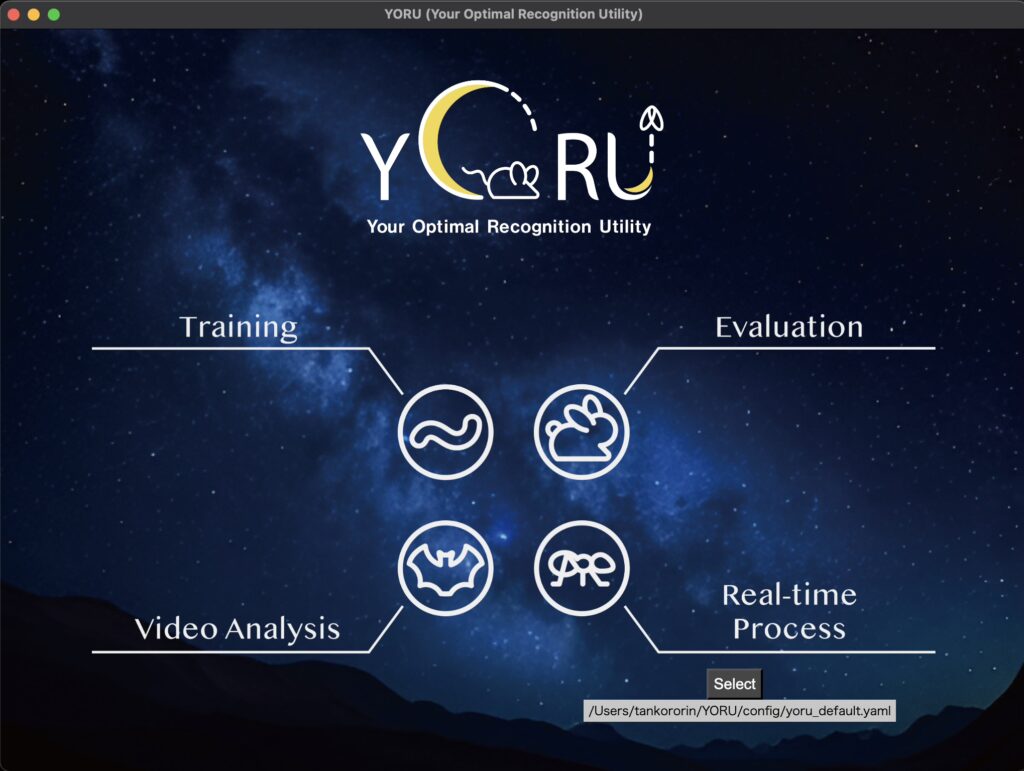
    Built-in real-time analysis

    Unusually for tools of this kind, YORU comes with a full GUI for real-time analysis.

    Building a real-time analysis system is not that hard if you can program to some degree, but otherwise the barrier is quite high.

    With YORU, however, you can carry out real-time analysis—and even fire external triggers—entirely without programming.

    Adaptable to a wide range of experimental setups

    The biggest hurdle in real-time analysis is figuring out how to combine the code that drives your own experimental apparatus with the analysis itself.

    YORU adopts a plugin system that lets you choose the program used to control your external devices.

    In other words, you simply select the plugin that matches your own system.

    You can also write your own plugins: simply turning your device’s control program into a plugin makes it easy to link that hardware to YORU’s real-time analysis.

    This makes for a remarkably user-friendly system that no other tool currently offers.

    Closing thoughts

    YORU has only just been released, so there are still rough edges in usability and clear gaps in the documentation.

    That said, as these are addressed over time, I am very much looking forward to seeing how people put it to use.

  • From GitHub Basics to Publishing Your Code Alongside a Paper

    Here are the slides from a talk I gave on how to use Git and GitHub.

    The slides cover everything from the basics of working with GitHub to the steps involved in publishing your code alongside a paper.

    Sharing paper data and analysis code is now routinely expected.
    Beyond that, managing code with GitHub has become an essential part of working on collaborative projects.

    [Updated January 15, 2024] https://www.slideshare.net/slideshow/embed_code/key/vzfmHD9i6I15wI

    From GitHub basics to code management and publishing your code with a paper from Hayato Yamanouchi

    The same material is also available on my personal site.

    Hayato M. Yamanouchi’s personal site

  • How to Install SLEAP [Updated February 2024]

    How to Install SLEAP [Updated February 2024]

    Here I’d like to walk through how to install SLEAP, a machine learning-based tool for tracking animal body parts.

    DeepLabCut is the best-known tracking tool, and I’ve written about how to install it myself in the past, while many others have posted articles about it as well.

    SLEAP, however, has relatively few articles written about it in Japanese.
    SLEAP has many advantages over DeepLabCut, so I decided to write up the installation procedure to make it a viable option for more people.

    SLEAP’s documentation covers everything from installation to usage very clearly, complete with videos, so anyone comfortable with English should find it easy to get started.

    The SLEAP paper is available here

    The official SLEAP website is here

    The SLEAP GitHub repository is here

    Introduction

    First, a note about the approach described in the official SLEAP installation guide:

    mamba create -y -n sleap -c conda-forge -c nvidia -c sleap -c anaconda sleap=1.3.3

    the one-line command that is supposed to handle environment creation, package installation, and everything else at once. I tried it on several computers, but in every case it hung indefinitely during the environment creation step and never completed.

    So in this post I’ll introduce the alternative installation method that the developers also suggest.

    Installation

    We’ll basically follow the installation instructions on the official SLEAP site.

    Environment

    ・Windows 11 Pro
    ・Verified on an NVIDIA 3080
    ・SLEAP 1.3.3
    ・Python 3.7.12

    Downloading the files

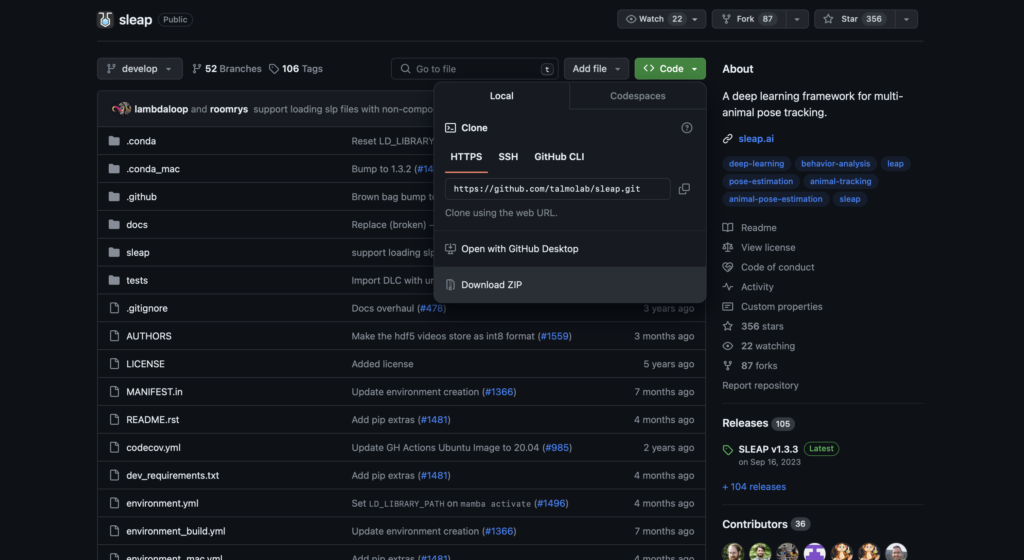
    First, download the files from the SLEAP GitHub repository to your computer.

    If you’re using Git, run the following command.

    git clone https://github.com/talmolab/sleap

    If the git command isn’t available, either install git or download the files directly from GitHub.

    Installing the GPU driver

    Install the NVIDIA driver.
    (Skip this step if it’s already installed.)

    Installing Anaconda

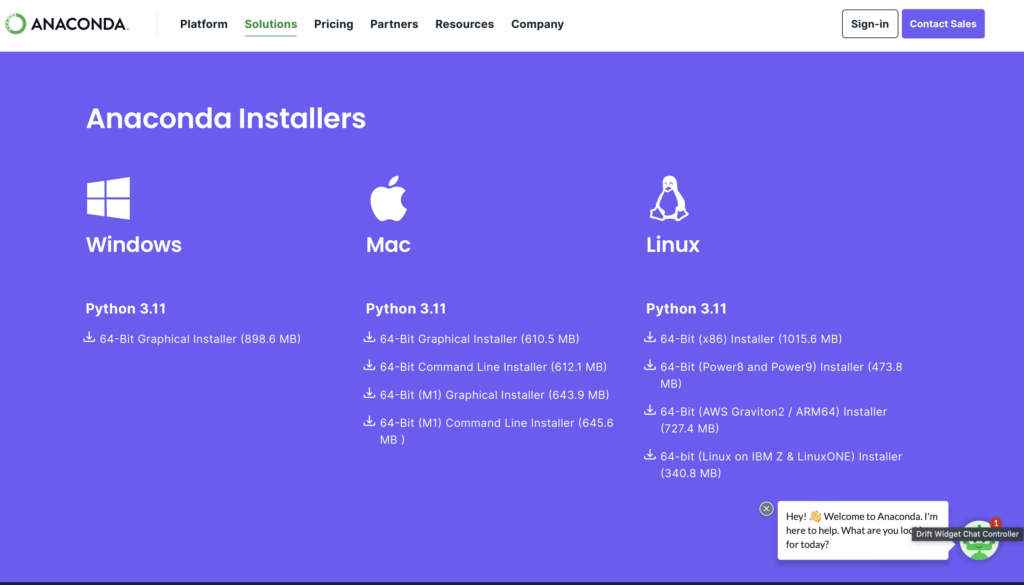
    Next, download and install the Windows 10 64-bit version from the Anaconda website.
    Click Free Download on the Anaconda site and scroll down; you’ll see a screen like the one below.
    Install the Windows installer on the far left.

    Once Anaconda is installed, you should find “Anaconda Prompt” in your Windows app list.
    We’ll use it to run the commands below to create the virtual environment, install the packages, and finally launch SLEAP.

    Creating the virtual environment and installing

    Next, run the following commands to create the virtual environment and install SLEAP.
    The environment will be named “sleap”.

    cd sleap
    conda env create -f environment.yml -n sleap

    Incidentally, the commands above work on computers with a GPU;
    on machines without one, use the following instead.

    cd sleap
    conda env create -f environment_no_cuda.yml -n sleap

    That completes the installation.

    Checking that the installation worked

    Activate the virtual environment and launch SLEAP with sleap-label.

    conda activate sleap
    sleap-label

    You’ll need to activate the virtual environment (the conda activate sleap command) every time you reopen Anaconda Prompt.

    After activating the environment, the prompt should change from (base) to (sleap).

    If it launches, the installation was successful.

    Checking version information for reporting in a paper

    To check the version, activate the sleap environment and then run the following command.

    python -c "import sleap; sleap.versions()"

    This outputs:

    SLEAP: 1.3.3
    TensorFlow: 2.7.0
    Numpy: 1.21.5
    Python: 3.7.12
    OS: Windows-10-10.0.22621-SP0

    which shows the SLEAP version and related information.

    To check whether SLEAP can use the GPU, run:

    python -c "import sleap; sleap.system_summary()"

    If the GPU is available, you’ll see output like the following.

    GPUs: 1/1 available
      Device: /physical_device:GPU:0
             Available: True
           Initialized: False
         Memory growth: None

    In future posts, I hope to walk through how to actually use SLEAP.

    Bonus

    For those who aren’t sure which computer to buy, I’ve started offering PC purchase consultations on Coconala!

    あなたの要望に合わせてパソコンを選び、提案します パソコン選びに困っている方々へ!様々な目的に対応できます!

    I often pick out computers and give advice about them, and many friends have told me I could make money doing PC consultations.
    That inspired me to give it a try!

    I’ll recommend a machine that fits both what you want to use it for and your budget.
    In particular, I’ve chosen and used many computers intended for machine learning.

    And if you’d like, I can also advise you on what to look for the next time you buy a computer.

    Computers I’ve picked out so far include lab analysis machines, everyday-use machines, game streaming machines, machines for incoming university students, machines that can run CAD for architecture students, and simple entry-level machines.

    I use both Mac and Windows, so I can discuss and recommend either one!

    Please feel free to make use of it.

  • [Updated December 2022] How to Install YOLOX

    [Updated December 2022] How to Install YOLOX

    What is YOLOX?

    Among the many entries in the YOLO series, the latest one, YOLOX, was released in July 2021.

    The YOLOX paper is available here (currently a preprint).
    The GitHub repository is here.

    YOLO is an object detection algorithm.
    It is designed to run in real time and is extremely lightweight (inference alone can even run on a smartphone). It is also highly adaptable, and is widely used in IoT devices.

    “Object detection algorithm” may sound complicated, but an easy analogy is a camera’s automatic face or eye focus.
    A marker appears indicating “this is a face”; the same idea applies to other objects, and the algorithm can also classify what each one is.

    There are many versions in the YOLO series: YOLO, YOLOv2, YOLOv3, YOLOv4, YOLOv5, and YOLOX.
    It also runs not only on Python but on MATLAB as well, so you can adapt it to whichever platform you use.

    Unlike the architecture used from YOLOv3 onward, YOLOX returns to the design of the original YOLO. It is reportedly faster and considerably more accurate.

    Other blogs cover the details as well.

    How to install YOLOX

    Installation instructions are given on the GitHub page, but they are in English and do not cover using a virtual environment, so here I explain how to do it with an Anaconda virtual environment.

    On both Windows and Mac, following the YOLOX manual exactly produced one error after another.
    Errors will likely keep changing with future versions, so look them up as they come.

    See below for how to use the conda command in the macOS Terminal.

    On Windows, I recommend using Anaconda Prompt.

    Open the Terminal (Anaconda Prompt), and you will get a black window filled with text.
    You should see (base) at the left of the last line.
    This means you are not currently inside a virtual environment.

    YOLOX will run without a virtual environment, but since environments can conflict with other packages, I recommend creating one.

    First, enter the following code to create a virtual environment.

    conda create -n YoloX python=3.8

    YoloX is the name of the virtual environment; you can use any name you like.
    You can also specify the Python version with python=3.8.

    Then activate the virtual environment with the following code.

    conda activate YoloX

    If (base) on the left has changed to (YoloX), you are all set.

    Installing CUDA

    First, if this is your first time installing machine learning libraries and you plan to train YOLO on a GPU, install CUDA.
    (Training on a CPU takes an absurdly long time, so I do not recommend it. Note that GPUs cannot currently be used on Apple Silicon machines.)
    CUDA can be downloaded from the official site.

    As for the CUDA version, I suggest checking which CUDA versions PyTorch supports and installing one of those.
    PyTorch official site

    To install an older version, click Download now and then, further down the page under Resources, use Archive of Previous CUDA Releases.

    The latest version may work too, but for now, matching the version to PyTorch should let you run everything without trouble.

    To check whether it is installed on Windows, open “Edit the system environment variables,” go to Advanced > Environment Variables, and see whether there is a path beginning with CUDA_PATH.
    The number after the V indicates the version.

    Installing PyTorch

    Before installing, update pip.
    Activate the virtual environment in Anaconda Prompt and run the following command.

    python -m pip install --upgrade pip

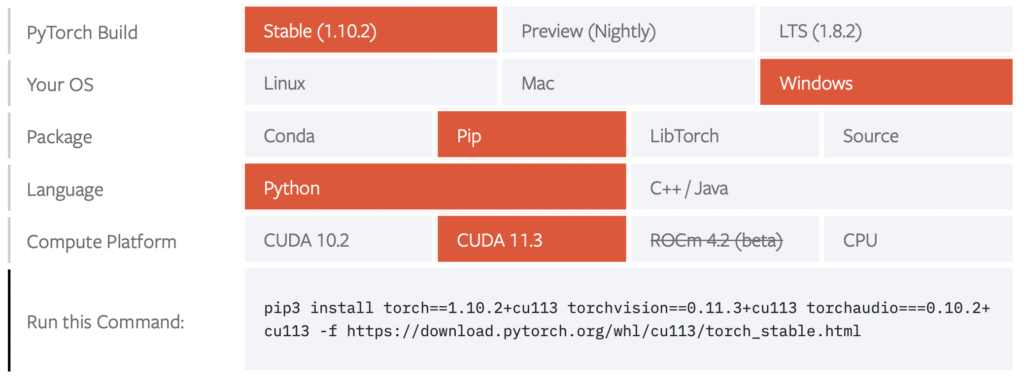
    Go to the PyTorch official site and choose the installation method that matches your environment.
    One catch here is the Package field: be sure to select pip.
    Installing with conda will cause errors later on.

    Copy and paste the command under “Run this Command” to install it in your virtual environment.

    Once the installation finishes, use the following command to check that PyTorch is installed.

    pip list

    As long as torch appears in the list, you’re good to go!!!
    As a quick check, start python and run the following command.

    import torch
    print(torch.cuda.is_available())

    If the output is True, the installation succeeded and torch is ready to run on the GPU.
    (On a Mac or on a computer without a GPU it will return False, but as long as the import works you’re fine.)
    If you get an error, go back and check the installation again.

    Installing the packages required for YOLOX

    Download (clone) the YOLOX files from GitHub.
    If you can use Git commands, you can clone the repository with the code below.

    git clone git@github.com:Megvii-BaseDetection/YOLOX.git

    Next, move into the cloned folder and install the required packages.

    First, edit the contents of requirements.txt in the cloned YOLOX folder as follows.

    # TODO: Update with exact module version
    numpy
    #torch>=1.7
    opencv_python
    loguru
    tqdm
    #torchvision
    thop
    ninja
    tabulate
    
    # verified versions
    # pycocotools corresponds to https://github.com/ppwwyyxx/cocoapi
    #pycocotools>=2.0.2
    #onnx==1.8.1
    onnxruntime==1.8.0
    onnx-simplifier==0.3.5

    It seems that packages such as pycocotools cannot be installed with this command.

    Once that’s done, save requirements.txt and run the command below in the terminal (Anaconda prompt).

    cd YOLOX
    pip3 install -r requirements.txt
    pip3 install cython pycocotools

    The downloaded YOLOX folder contains a file called “requirements.txt” that lists the required packages. The second command opens this file in read-only mode and installs the packages listed in it.

    pip3 install cython pycocotools

    This command installs cython and pycocotools.
    It seems these have to be installed separately.

    When you run this command, some of you may see the following error.

          building 'pycocotools._mask' extension
          error: Microsoft Visual C++ 14.0 or greater is required. Get it with "Microsoft C++ Build Tools": https://visualstudio.microsoft.com/visual-cpp-build-tools/

    Microsoft C++ Build Tools is apparently required by pycocotools. (Oddly enough, the error also appears on Mac, even though there is no Mac version.)
    Windows users should install it just to be safe.

    After installing it, try the installation again with the code below.

    pip3 install "git+https://github.com/philferriere/cocoapi.git#egg=pycocotools&subdirectory=PythonAPI"

    If that still doesn’t work, install it with the following command.

    conda install -c conda-forge pycocotools

    In general we’ve been installing these packages with pip, but since this one simply won’t install that way, we resort to installing it with conda.

    Next, download yolox_x.pth.
    The download starts as soon as you click the link.

    Move the downloaded file into the YOLOX folder you cloned from GitHub.
    This gives you the model used for detection in the demo, placed wherever you like.

    Add the following lines to the top of tools/demo.py so that the yolox folder can be accessed.

    #demo.pyの中身に書き込みましょう。
    import sys
    import os
    sys.path.append(os.path.join(os.path.dirname(__file__), '..'))

    Without this, you’ll get an error saying the yolox package cannot be found.

    Then run the following command in the terminal.
    This lets you check whether the demo runs correctly.

    python tools/demo.py image -n yolox-x -c yolox_x.pth --path assets/dog.jpg --conf 0.25 --nms 0.45 --tsize 640 --save_result --device gpu 
    #gpuで動かさない場合には、gpuをcpuに書き換えてください。

    Replace –device gpu with –device cpu as appropriate for your setup.

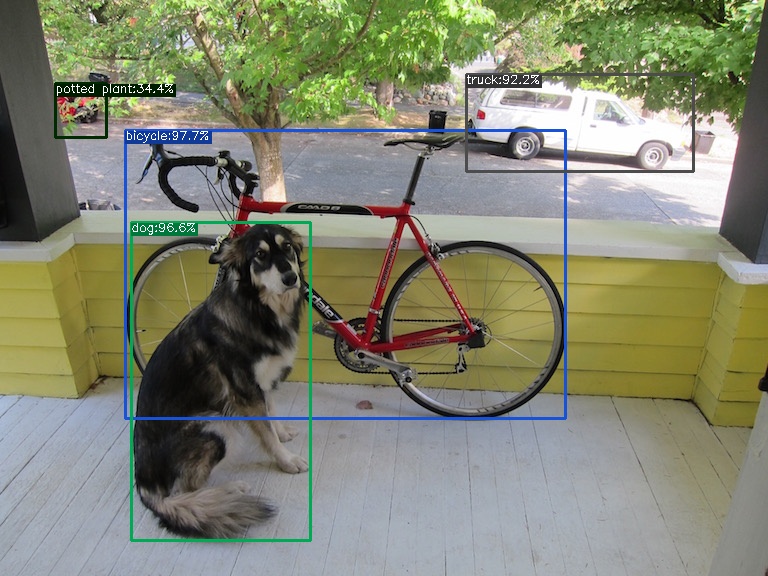
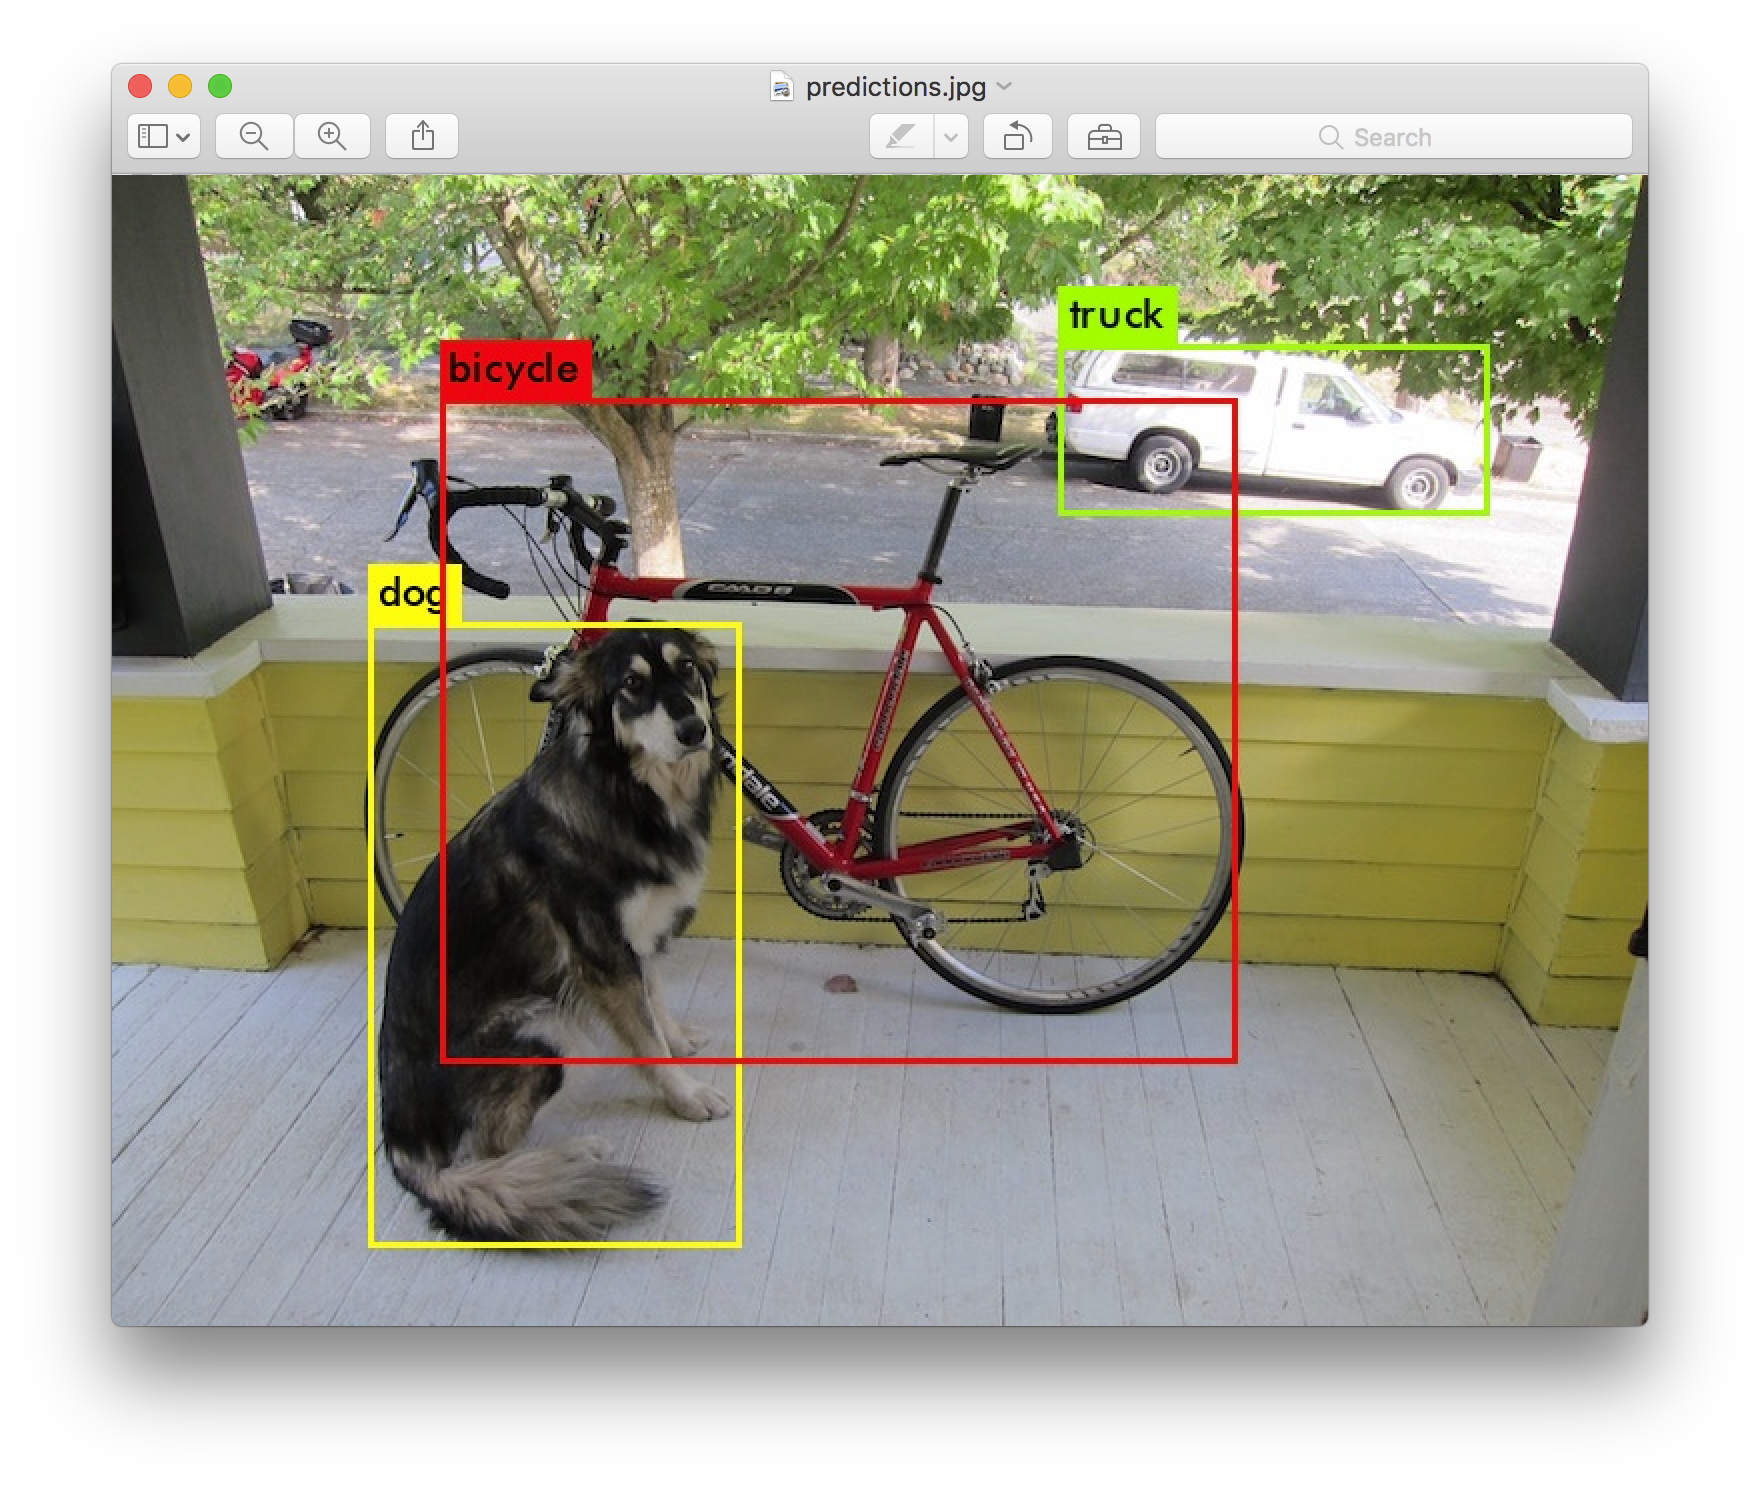
    If the following image appears in YOLOX/YOLOX_outputs/yolox_x/vis_res/20…….., everything is working.

    Bonus

    For those who aren’t sure which computer to buy, I’ve started offering PC purchase consultations on Coconala!

    あなたの要望に合わせてパソコンを選び、提案します パソコン選びに困っている方々へ!様々な目的に対応できます!

    I often pick out computers and give advice, and many friends told me I could make money doing PC consultations.
    Inspired by that, I decided to give it a try!

    I’ll recommend a machine that fits how you plan to use it and your budget.
    In particular, I’ve chosen and used many computers for machine learning.

    And if you’d like, I can also advise you on what to look for the next time you buy a computer.

    Computers I’ve picked out so far include analysis machines for the lab, everyday-use machines, game-streaming machines, machines for incoming university students, machines that can run CAD for architecture students, and simple all-purpose machines.

    I use both Mac and Windows, so I can talk about and recommend either!

    Please feel free to make use of it.

  • My elif conditional branching isn’t working!! [Python]

    My elif conditional branching isn’t working!! [Python]

    Have you ever wanted to branch on multiple conditions with an if statement, tried using elif, and found that although no error appears, the results somehow aren’t what you expected?
    If so, the situation described below might be the cause.
    For reference, since I made this mistake myself, I’m writing it down as a note.

    The problematic program

    The problem arises when you write two conditions in the if and elif statements and build a program that includes elif.

    def trable(a, b):
        if a >= 10 & b >= 10:
            print("patern A")
        elif a >= 10 & b < 10:
            print("patern B")
        elif a < 10 & b >= 10:
            print("patern C")
        else:
            print("patern D")
    
    trable(11, 11)
    trable(11, 9)
    trable(9, 11)
    trable(9, 9)

    When you run the program above, you might expect the cases to be sorted into patterns A, B, C, and D in order from the top, but the actual output is as follows.

    patern A
    patern B
    patern C
    patern B

    What if we swap the order?

    def trable(a, b):
        if a >= 10 & b >= 10:
            print("patern A")
        elif a < 10 & b < 10:
            print("patern B")
        elif a >= 10 & b >= 10:
            print("patern C")
        else:
            print("patern D")
    
    trable(11, 11)
    trable(9, 11)
    trable(11, 9)
    trable(9, 9)

    If you swap the code for patterns B and C and write a program that you expect to output A, B, C, and D, the actual output is as follows.

    patern A
    patern D
    patern D
    patern D

    elif itself is used as shown below when you want to define multiple conditions.

    if 条件式A:
      条件式Aが真(True)となった場合の処理
    elif 条件式B:
      条件式Aが偽(False)で、条件式Bが真(True)となった場合の処理
    else:
      条件式Aが偽(False)で、条件式Bも偽(False)となった場合の処理

    However, once the conditional expressions in the if and elif statements involve two conditions, the problem described above is likely to occur.
    As a result, you don’t get the output you intended.

    The tricky part is that no error is raised, so you can’t tell whether it worked until you actually look at the results.

    How to fix it

    When you want to branch into multiple cases using multiple conditions, avoid specifying multiple conditions in an elif statement.

    def resolve(a, b):
        if a>= 10:
            if b >= 10:
                print("patern A")
            else:
                print("patern B")
    
        else:
            if b >= 10:
                print("patern C")
            else:
                print("patern D")
    
    resolve(11, 11)
    resolve(11, 9)
    resolve(9, 11)
    resolve(9, 9)

    It becomes more cumbersome, but doing it this way produces exactly the output you expect.

    Programming has unexpected pitfalls like this, so it’s a good lesson in carefully checking the code you write.

    Addendum (August 2022)

    It turns out the problem was not wrapping the conditions in parentheses.

    def trable(a, b):
        if (a >= 10) & (b >= 10):
            print("patern A")
        elif (a < 10) & (b < 10):
            print("patern B")
        elif (a >= 10) & (b >= 10):
            print("patern C")
        else:
            print("patern D")

    With this change, the branching worked correctly.
    Alternatively, you can also solve it by writing and instead of &.

    def trable(a, b):
        if a >= 10 and b >= 10:
            print("patern A")
        elif a < 10 and b < 10:
            print("patern B")
        elif a >= 10 and b >= 10:
            print("patern C")
        else:
            print("patern D")

    & and and may seem the same, but & also acts as a bitwise AND, so in the original program

    a >= 10 & b < 10

    this apparently means a >= (10 & b) < 10, so with a=9 and b=9 the inequality becomes
    9>=8<10, which evaluates to True.

    It’s tricky, isn’t it…

  • [Updated December 2022] How to Install YOLOv5 [Object Detection Tool]

    [Updated December 2022] How to Install YOLOv5 [Object Detection Tool]

    What is YOLOv5?

    YOLO is an object detection algorithm. The name stands for You Only Look Once.
    It differs somewhat from object tracking: it detects objects and identifies what they are.

    YOLOのHPより引用(https://pjreddie.com/darknet/yolo/)

    In applications such as autonomous driving, objects are detected and classified the way a human would judge them—as a person, a pet, or a car, for example.

    The classification algorithm itself is complex, so I will skip the explanation here, but a quick search turns up a great many sites that describe it.

    New versions of YOLO are currently released roughly every other year. We now have YOLO v1 through YOLOv5, and in August 2021 a new version, YOLO X, was announced.
    The differences between versions involve substantial changes in the details, but generally speaking accuracy improves with each new release.

    Here I will walk through the steps for installing YOLO v5—which offers ample accuracy and, thanks to the wealth of information now available, is easy to set up—and verifying that it works.

    Installation environment

    OS: Windows 10 (this also worked on macOS Monterey)
    Python: 3.9.7 (3.6 or later)
    CUDA: 11.3

    How to install

    Creating a virtual environment

    Create a virtual environment using Anaconda.
    If you do not have Anaconda installed, install it first.

    Installing YOLOv5 pulls in quite a few packages, so I recommend installing it inside a virtual environment.
    You can name the environment anything you like; here we will call it “Yolov5_env”.
    Enter the following command in Anaconda Prompt.

    conda create -n Yolov5_env python=3.9

    This should create the virtual environment.
    Activate it with the following command.

    conda activate Yolov5_env

    Installing CUDA

    First, if this is your first time installing machine learning libraries and you plan to train YOLO on a GPU, install CUDA. (Training on a CPU takes an absurdly long time, so I do not recommend it.)
    CUDA can be downloaded from the official site.

    As for which CUDA version to use, I suggest checking which CUDA versions PyTorch supports and installing that version.
    PyTorch official site

    To install an older version, click Download now and then, on the resulting page, use Archive of Previous CUDA Releases under Resources further down the page.

    The latest version may well work too, but for now, matching the version PyTorch expects should let you run everything without trouble.

    To check whether it is installed on Windows, open “Edit the system environment variables,” go to Advanced > Environment Variables,
    and look for a path beginning with CUDA_PATH.
    The number after the V indicates the version.

    Installing PyTorch

    Before installing, update pip.
    Activate the virtual environment in Anaconda Prompt and run the following command.

    python -m pip install --upgrade pip

    Go to the PyTorch official site and choose the installation options that match your environment.
    One thing to watch out for is the Package field: be sure to select pip here.
    Installing with conda will cause errors later on.

    Copy and paste the command shown under “Run this Command” to install it into your virtual environment.

    Once the installation finishes, use the following command to confirm that PyTorch is installed.

    pip list

    If torch appears in the list, you are good to go!
    As a quick check, start Python and run the following command.

    import torch
    print(torch.cuda.is_available())

    If the output is True, the installation succeeded and torch is ready to run on the GPU.
    (On a Mac or a computer without a GPU you will see False, but as long as the import goes through, you are fine.)
    If you get an error, go back and review the installation.

    Installing YOLOv5

    Download (clone) the YOLOv5 files from GitHub.

    git clone https://github.com/ultralytics/yolov5

    If you cannot use the git command, either install git or download the files from the YOLOv5 GitHub repository.

    Next, run the following command in your virtual environment in Anaconda Prompt.

    cd yolov5
    pip install -r requirements.txt

    The first command moves you into the yolov5 folder you downloaded from GitHub. If you installed it with the git command, this is all you need; if you downloaded it directly from the website, you will have to navigate to that directory yourself.

    The downloaded yolov5 folder contains a file called “requirements.txt” that lists the required packages. The second command opens this file in read-only mode and installs the packages listed in it.

    Once the installation is finished, let’s check which packages were installed.

    pip list 

    You should see that quite a few packages were installed.
    That completes the installation of YOLOv5 for now.

    Running It

    To check that everything works, let’s try it with the data that comes with the yolov5 folder.
    Open Anaconda Prompt, activate the virtual environment, and use the cd command to move to the yolov5 folder.

    Then run the following command.

    python detect.py --source ./data/images/ --weights yolov5s.pt --conf 0.4

    detect.py is the program that performs object detection using YOLO.
    With source, you specify the path to the folder containing the material you want analyzed.
    Here I used the images included in yolov5.

    With weights, you choose which model to use.
    Here we use yolov5.pt.

    conf sets the likelihood threshold at which an object is recognized.
    This is a term you will run into often when studying machine learning.
    If you are not sure, leaving it as is should be fine.

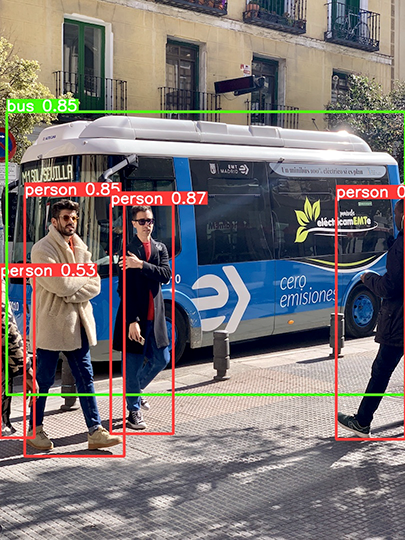
    After running it, you should find the annotated images in runsdetectexp inside the yolov5 folder.
    This is how object detection works in YOLOv5.

    Errors I Ran Into

    ・ModuleNotFoundError: No module named ‘torch’

    You may see this error when trying to run YOLO.
    It means PyTorch is not available, i.e., the module cannot be found.

    If you get this error, first check whether torch is installed in your virtual environment.

    pip list

    If torch is not listed, install PyTorch.
    If it is there but things still do not work and you are not sure why, launch python, import PyTorch, and check whether it can actually be used.

    import torch
    torch.cuda.is_acailable()

    If it is usable, True will be returned; if not, you will likely see the error above.

    One possible cause of this error is that PyTorch was installed with the conda command.
    If PyTorch is installed via conda while the other packages are installed via pip, the error above can occur.

    In that case, uninstall torch with the conda command and reinstall it with pip.

    Module-not-found problems often come from mixing up whether you installed something with pip or with conda.
    Here we use pip throughout, but it is a good habit to always keep track of which command you used to install a package.

    Links

    Anaconda
    CUDA
    PyTorch
    YOLOv5 GitHub
    YOLO homepage

    Bonus

    For those who aren’t sure which computer to buy, I’ve started offering PC purchase consultations on Coconala!

    あなたの要望に合わせてパソコンを選び、提案します パソコン選びに困っている方々へ!様々な目的に対応できます!

    I often pick out computers and give advice, and many friends have told me I could make money doing PC consultations.
    That inspired me to give it a try!

    I’ll recommend a machine based on what you plan to use it for and your budget.
    In particular, I’ve chosen and used many computers for machine learning.

    And if you’d like, I can also advise you on what to look for the next time you buy a computer.

    Computers I’ve picked out so far include analysis machines for the lab, everyday machines, PCs for game streaming, PCs for incoming university students, CAD-capable PCs for architecture students, and simple all-purpose machines.

    I use both Mac and Windows, so I can discuss and recommend either!

    Please give it a try!

  • How to Install labelImg [Updated December 2022]

    How to Install labelImg [Updated December 2022]

    When doing object clustering, you may sometimes want to use your own trained model rather than just the models that already exist.

    YOLO is a well-known tool for object clustering, and labelImg (written LABELIMG in capitals) is extremely useful when creating the training data for it.

    Here I introduce how to install labelImg.

    Environment

    OS: Windows 10 (it also worked on macOS Monterey)
    Python: 3.9.7 (3.6 or later)

    How to install

    I recommend creating a virtual environment with Anaconda and installing it there.
    That way you can install it without affecting your other environments.

    The name of the virtual environment can be anything as long as you can recognize it, but here we will use “labelimg_env”.
    Run the following command in the Anaconda prompt.

    conda create -n labelimg_env python=3.9

    Here I am installing with Python 3.9, but any version from 3.6 onward should be fine.

    Next, update pip and setuptools.
    Doing this should prevent mysterious errors (probably).

    python -m pip install --upgrade pip setuptools

    Then install labelImg.

    pip install labelImg

    You can check whether it was installed with the following command.

    pip list

    If labelImg appears in the list, the installation was successful.

    Launching

    First, activate the virtual environment.

    conda activate labelimg_env

    Then launch labelImg.

    labelImg

    If a separate window opens, you’re all set!!

    Afterword

    LabelImg’s GUI is built with PyQt5.
    The reason Python 3.6 or later is preferable is that the current version of PyQt5 requires Python 3.6 or later.

    In general, the latest version should work fine.

  • Changing Pulse Wave Frequency and Duty Cycle Using PWM Output [Arduino UNO]

    Changing Pulse Wave Frequency and Duty Cycle Using PWM Output [Arduino UNO]

    What is PWM output?

    PWM stands for pulse width modulation. It is a modulation method that works by changing the duty cycle of a waveform.

    For details, see my previous post.

    PWM output on Arduino

    The Arduino UNO uses a Microchip microcontroller called the ATmega328 as its main chip.
    Once you start digging deep into Arduino programming, you inevitably end up having to read the microcontroller’s datasheet, so it is worth taking a look at least once. (Which is exactly what I am doing now.)

    The Arduino has three timers (Timer/Counter).
    These timers govern all timing in an Arduino program.
    Functions such as delay() and tone() are measured using them.

    Timer/CounterPin numberBitsRolePWM frequency
    Timer05, 68 bitManages Arduino timing
    delay(), millis(), micros(), etc.
    977 Hz
    Timer19, 1016 bitServo library, etc.490 Hz
    TImer23, 118 bittone(), etc.490 Hz

    This time we will change the PWM output by manipulating these timers.
    Incidentally, since this alters the timers at their core, with some ingenuity you might also be able to tweak functions like delay() to your liking. (Although it seems more likely that they will simply be thrown off and behave erratically.)

    Timer0 is generally tied to the system as a whole, so I recommend using Timer1.

    Useful references
    https://playground.arduino.cc/Main/TimerPWMCheatsheet/
    https://www.arduino.cc/en/Tutorial/SecretsOfArduinoPWM
    https://atooshi-note.com/arduino-1hz-pwm/
    http://blog.kts.jp.net/arduino-pwm-change-freq/
    http://garretlab.web.fc2.com/arduino/inside/hardware/arduino/avr/cores/arduino/wiring_analog.c/analogWrite.html

    Program overview

     The overall approach is to change the register settings of the Arduino’s timers so that the PWM output frequency can be set freely.

    The goal is to be able to output low frequencies, so the program is written to output 10 Hz.

    Here we connect an LED to pin 10 and write a program that lets us freely change the frequency and duty cycle of its light.
    Since we are using pin 10, we will use Timer1.

    Program code

    //レジスタの設定を変えるためのもの
    #include <avr/io.h>
    int PWMPin = 10;
    
    //関数の定義
    //frq:周波数 (1Hz~指定できる)
    //duty:指定したいduty比
    void HzWrite(int frq, float duty) { 
    
        // モード指定
      TCCR1A = 0b00100001;
      TCCR1B = 0b00010100; //分周比256を用いる
    
      // TOP値指定
      OCR1A = (unsigned int)(31250 / frq);
    
      // Duty比指定
      OCR1B = (unsigned int)(31250 / frq * duty);
    }
    
    
    void setup() {
      pinMode(PWMPin, OUTPUT);
    }
    
    void loop() {
      HzWrite(10, 0.5);
      delay(5000);
      digitalWrite(PWMPin, LOW);
      delay(5000);
    
    }

    Explanation of the program

    First, include <avr/io.h> so that we can change the register settings.

    #include <avr/io.h>

    Next, to build a function that works together with delay() to repeat a 10 Hz output every five seconds, we define a function called HzWrite. Its arguments let us specify the frequency and the duty cycle.

    void HzWrite(int frq, float duty) { 
    
    }

    Next comes the mode setting.
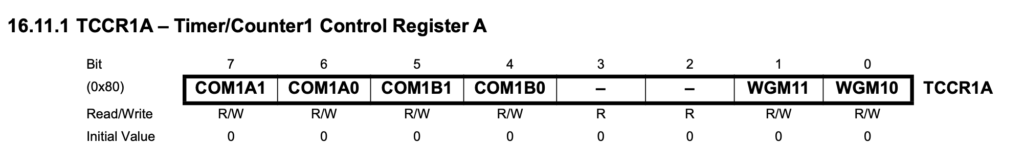
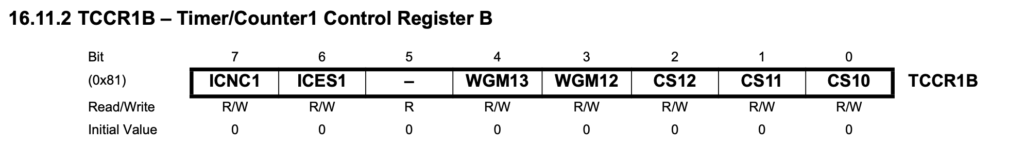
    The registers used here are TCCR1A/TCCR1B. (TCCR: Timer/Counter Control Register)
    The “1” indicates Timer1; if you want to use Timer2, use TCCR2A/TCCR2B instead.

    To set the PWM frequency to a specific value in Hz, you need to specify the TOP value yourself.
    The larger the TOP value, the lower the output frequency.
    Here we use 10 Hz as an example. Since this is very slow compared with the 16 MHz system clock, a large TOP value and a large prescaler are required. For this reason we use Timer1, which offers the largest range.


    With the 8-bit Timer0 and Timer2, the maximum TOP value is 255 (2^8 – 1), whereas with the 16-bit Timer1 it is 65535 (2^16 – 1).
    (The maximum is one less because the range is 0–255 or 0–65535: the number of values is 2^x, but the largest value is 2^x – 1.)

    Internally, the counter increments (0, 1, 2, …) up to the TOP value, and when it matches OCRxA/OCRxB (x is the counter number; each counter has two output pins, A and B) the pin output changes (e.g., LOW→HIGH). Once the counter reaches the TOP value, it then decrements back down to 0 (65535, 65534, 65533, …), and just as during the increment phase, the pin output changes when the count matches OCRxA/OCRxB.

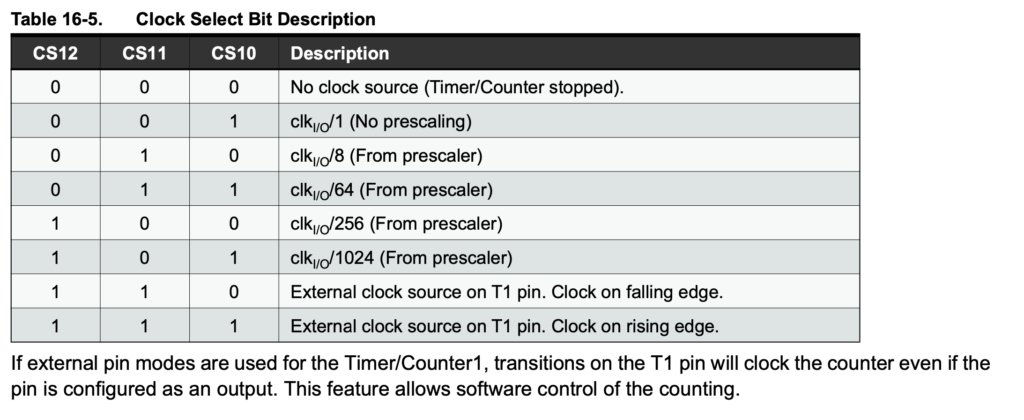
    On the Arduino UNO you can change how fast this counter increments, to some extent, by changing the prescaler setting. (“To some extent” means you can choose from 1/8/64/256/1024.)
    The prescaler is the ratio (n) used when dividing the frequency (multiplying it by 1/n).
    In other words, dividing 1000 Hz by a prescaler of 10 gives 100 Hz.

    Incidentally, with a prescaler of 1 the timer runs at 16 MHz, the system clock of the Arduino UNO (ATmega328).

    In short, by changing the TOP value, the OCRxA/OCRxB values, and the prescaler, you can freely control the points at which the output switches.

    Since we want 10 Hz here, we use a prescaler of 256 to leave plenty of margin.
    On the Uno the clock is 16 MHz, so one count takes 1 / 16 MHz = 62.5 ns (prescaler 1).
    With a prescaler of 256, counting all the way to TOP takes 62.5 ns x 256 x 65535 = 1.04856 s, so frequencies as low as 1 Hz can be specified.

    This program can generate frequencies from 1 Hz to 31250 Hz.
    However, as you approach 31250 Hz it becomes impossible to specify the duty cycle precisely.
    If you want fine control over the duty cycle, you can only go up to about 300 Hz.

    By changing the prescaler setting in this program, you can build a version that covers the frequency range suited to your own application.

    In TCCR1A/TCCR1B you write what you want to configure.
    The details here are rather involved, so let’s work through them roughly using the datasheet.

    Here the values are given in binary, so they start with 0b. For TCCR1A you set COM1A1, COM1A0, COM1B1, COM1B0, unused, unused, WGM11, WGM10 to 1 or 0.
    For TCCR1B you set unused (ICNC1), unused (ICES1), unused, WGM13, WGM12, CS12, CS11, CS10.

    TCCR1Aの指定(ATmega328データシートより)
    TCCR1Bの指定(ATmega328データシートより)

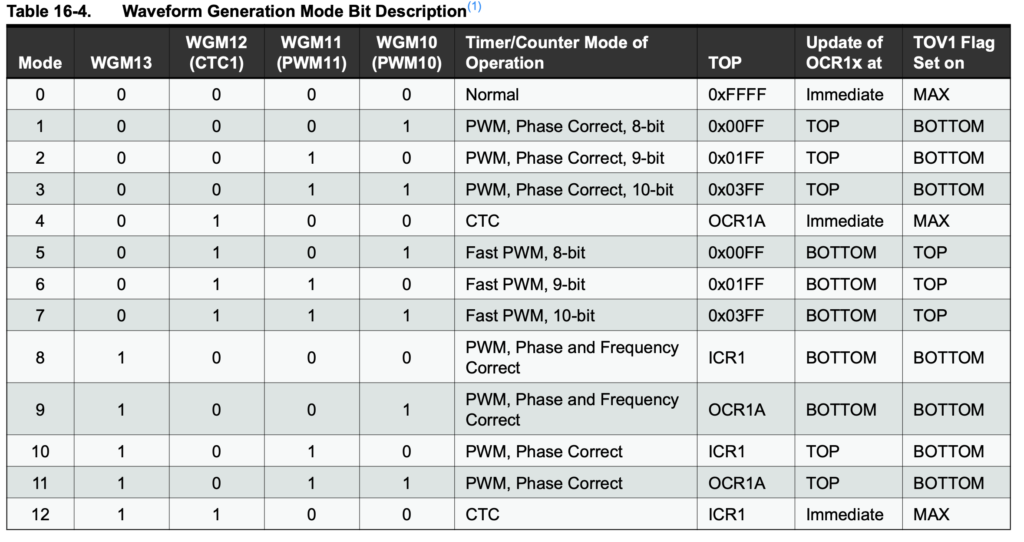
    First, here we choose Mode 9, whose PWM mode is Phase and Frequency Correct.
    In this case the TOP value is set in OCR1A.

    モードの指定(ATmega328データシートより)

    Therefore WGM13 / WGM12 / WGM11 / WGM10 are 1, 0, 0, 1, respectively.

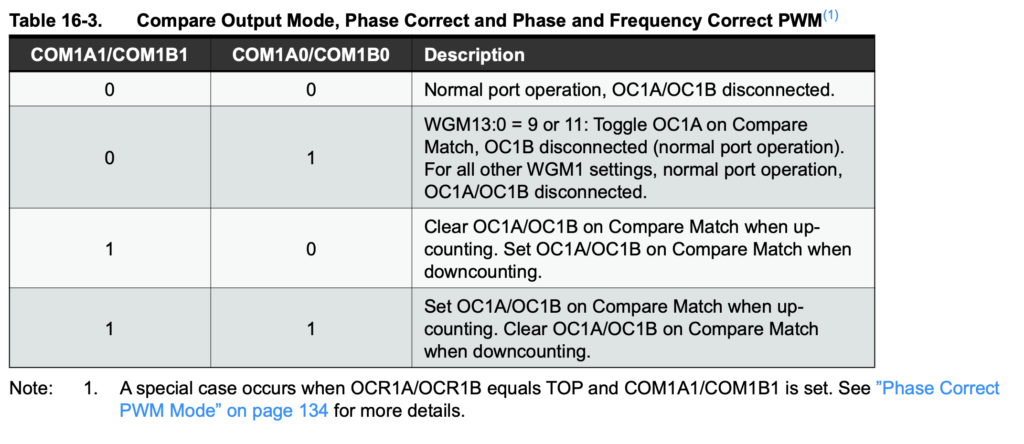
    出力の指定(ATmega328データシートより)

    For COM1B1 / COM1B0: 0, 0 means no output; 0, 1 means toggle operation (the output is inverted on compare match);
    1, 0 outputs LOW while the counter is between OCR1A/B and TOP and HIGH while it is between 0 and OCR1A/B;
    1, 1 is the inverse of 1, 0.

    Here we drive the output LED between LOW and HIGH at the desired frequency, so COM1B1 / COM1B0 are set to 1, 0.

    We choose 1, 0 because it makes the sketch easier to follow.

    分周比の指定(ATmega328データシートより)

    Since we are using a prescaler of 256 here, CS12/CS11/CS10 are set to 1, 0, 0.

    To summarize, we get the following.

    TCCR1A = 0b00100001;
    TCCR1B = 0b00010010;

    Next we set OCR1A and OCR1B so that the output is generated with the specified frequency and duty cycle.

      // TOP値指定
      OCR1A = (unsigned int)(31250 / frq);
    
      // Duty比指定
      OCR1B = (unsigned int)(31250 / frq * duty);

    Because Phase and Frequency Correct PWM counts up and then back down, the output frequency is given as follows.

    Frequency frq = IC clock frequency / (prescaler * TOP value * 2)

    Conversely, to determine the TOP value:

    TOP value = IC clock frequency / (prescaler x frq x 2)

    With a prescaler of 256 on the Arduino UNO, this gives

    TOP value = OCR1A = 16,000,000 / (256 x frq x 2) = 31250 / frq

    Since we want the LOW/HIGH switching point to be given by OCR1A/OCR1B = duty cycle,

    OCR1B = 31250 / frq x duty

    Unsigned int is used to prevent overflow.

    Here is the main output routine.

    void setup() {
      pinMode(PWMPin, OUTPUT);
    }
    
    void loop() {
      HzWrite(10, 0.5);
      delay(5000);
      digitalWrite(PWMPin, LOW);
      delay(5000);
    
    }

    Set PWMPin, i.e., pin 10, as OUTPUT, and specify the frequency and duty cycle with HzWrite().
    After waiting with delay(), turn the output off with digitalWrite(PWMPin, LOW) and call delay() again.

    That covers the full program and how it works.

    Afterword

    When looking for blog posts on how to change the PWM output frequency, I found far more results by searching for AVR, ATmega328, or 328P than by searching for Arduino.

    This post was only a rough overview, so if you want to dig deeper, I encourage you to look into it yourself.

  • How to Generate Continuous Pulse Waves with Arduino

    How to Generate Continuous Pulse Waves with Arduino

    Introduction

    There are times when you want to output a continuous pulse wave with an Arduino: blinking an LED, producing a sound, using it as a timer, and so on.

    It comes up often and seems simple at first, but the more you look into it, the deeper the topic gets.

    In this post, I introduce several ways to output a continuous pulse wave with an Arduino.

    Changing the timing with delay

    The simplest and easiest approach is to switch the output ON and OFF using the delay function.

    //pinはピン番号
    void loop(){
        digitalWrite(pin, HIGH);
        delay(1000);
        digitalWrite(pin, LOW);
        delay(1000);
    }

    In the program above, the output alternates between HIGH and LOW.
    Since delay is specified in milliseconds, delay(1000) waits for one second.

    In other words, it is a program that turns on and off at 1 Hz.

    However, using the delay() function to set a frequency has many drawbacks.
    With this approach, changing the output duration—say, outputting a 60 Hz signal for 5 seconds—requires a for loop, which is inconvenient.

    That said, because it is so simple, I recommend it when you just want to try something out quickly.

    Using tone()

    The tone() function is commonly used to generate buzzer sounds.
    Official Arduino reference

    This function lets you specify the frequency and the duration.
    So, unlike the delay approach, you can specify the frequency directly without having to calculate it.

    //pinはピン番号
    void loop() {
         tone(pin,60);
    }

    You can write it as tone(pin, frequency) or tone(pin, frequency, duration).

    The duration is given in milliseconds, so it is written the same way as delay.

    The problem with this function is that it cannot produce frequencies of 31 Hz or below.
    In other words, you cannot generate an output at, say, 1 Hz.

    For frequencies above 31 Hz, such as audio tones, it makes setting the frequency very easy, and the code is far shorter and more accurate than using the delay function.

    Using PWM output and changing its frequency

    Using PWM output offers the most flexibility—and it is also the reason this topic gets so deep.

    PWM stands for pulse width modulation.
    For details, see Wikipedia.

    The term alone does not tell you much, but in simple terms, PWM is a way of modulating an output by changing the duty ratio.
    The official Arduino explanation is here.

    Normally, you would set the brightness of an LED by changing the current.
    But when the current is fixed and you still want to change the brightness, you blink the LED at a very high frequency (the flicker fusion threshold for humans is said to be around 30–60 Hz).

    Normally the ON and OFF periods are 1:1 (a duty ratio of 50%), but what happens if you make it 4:1 (80% duty) or 1:4 (20% duty)?
    The former looks bright, and the latter looks dim.

    Modulating the output by changing the pulse width in this way is what PWM output is.

    On the Arduino you can not only produce this output but also change the PWM frequency.
    The idea behind this method is that by changing register settings—that is, the underlying parts of the Arduino—you can change the PWM output frequency.
    By default, the output frequency is 490 Hz, or 980 Hz on some pins.

    I will explain how to do this in detail in a future post.
    Searching for “PWM Arduino change frequency” turns up plenty of explanations.

    After reading through them about four times, it starts to make sense.

    Basically, why not try these approaches and find the one that fits your own purpose?

  • How to Install Python Video Annotator

    How to Install Python Video Annotator

    What is Python Video Annotator?

    Python Video Annotator is an application that lets you analyze recorded videos and annotate events within them along a timeline.

    Researchers in neuroscience and ethology can use it to record videos of animals and then analyze and quantify their behavior.
    For example, suppose you are recording mouse behavior and want to score events such as tongue extension, tail flicks, or ear movements.
    When does each event occur in the video, and how long does it last?
    Watching the video and logging everything in Excel each time quickly becomes overwhelming when you have defined many behaviors.
    With a tool like this, you can annotate the video directly and export the timing and event information.

    There used to be an open-source application for scoring animal behavior called VCode.
    The problem, however, is that it no longer runs on current computer operating systems.

    Python Video Annotator runs on modern PCs, retains the features you need, and can additionally be combined with external sensor data (such as pressure gauges) and behavior quantification tools like DeepLabCut, making it a very useful tool for researchers.

    How to install

    The official site describes the installation procedure in detail, but I could not get it to install properly on my machine. (Installing it directly may have caused conflicts with packages already present on my system.)
    So instead I followed the approach described on the GitHub page: building a virtual environment with Anaconda and installing there.

    It sounds complicated when written out, but the steps are actually very simple.
    As of now (October 20, 2021) it does not appear to support the latest macOS (Big Sur 11.6), though this will likely be fixed soon.
    For that reason, I will use Windows as the example here.

    That said, once you have installed Anaconda on macOS and can use the conda command, the steps are essentially the same, so please refer to this guide once support arrives. (For details, see my previous post.)

    Install Anaconda and open the Anaconda Prompt.
    Then create a virtual environment and activate it.

    conda create -n videoannotator python=3.6
    conda activate videoannotator

    Next, install the required packages.

    pip install opencv-python-headless pyqt5==5.14.1 pyqtwebengine==5.14.0

    Then install Python Video Annotator.

    pip install python-video-annotator

    Once the various processes finish, the installation is complete.

    To launch it, activate the virtual environment first, then run the command.

    conda activate videoannotator
    start-video-annotator

    If the software starts up, you are all set.